• Blog
  • Archives
  • Bio
  • Awards
  • Speaking
  • Book
  • Contact

Jevaroo’s neck

Published: Monday, 23 May 2022

Jevaroo’s neck is my favorite part of the robot.
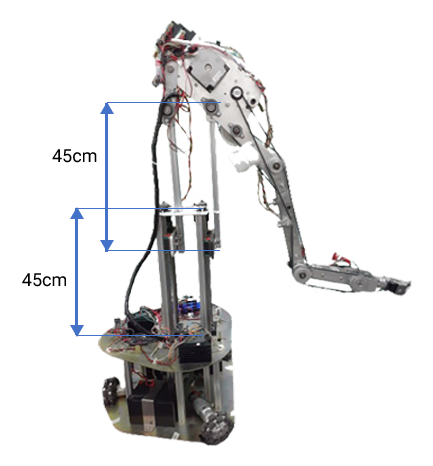
Jevaroo’s neck has a movement range of 25cm, allowing Jevaroo to reach for objects up to 170cm high while outstretched at full extension, and all the way down on the floor at no extension.  It is able to do that due to the innovative double linear actuator design, which creates a levered effect.
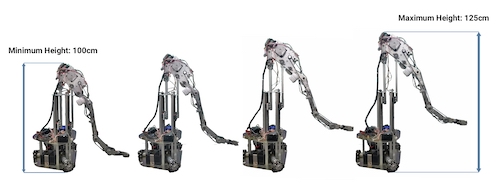
When both linear actuators move at the same height and the same speed, the limb is able to travel up and down uniformly in order to hold for example, a container of liquid steadily at the same height without spillage.  In fact, even when the linear actuators move in uniform in the same direction at different heights, the robot limb is able to maintain its end-effector position - Jevaroo would still be able to maintain its end-effector position as it moves around. 

To change the angle of the limb, one linear actuator may be stationary, while the other is in motion, changing the tilt angle for the entire limb.  To increase the speed of change for the end effector to get into its new position, both linear actuators may move in opposition directions. 

The linear actuators are capable of great speeds and great forces, while being bottom-heavy, with the motors of the linear actuator at the base of the robot, increasing stability.  The levered design is an inspired choice, increasing motion capability, increasing the robot’s upward force and adding stability against loads on the robot arm.
About Me

Marita ChengForbes named me a world's top 50 woman in tech & 30 Under 30. I founded Robogals and Aipoly and was Young Australian of the Year 2012. Currently working on robotics company Aubot. I'm the youngest Member of the Order of Australia (AM) and I give speeches around the world.

I tweet @maritacheng and I'm on Facebook.

Subscribe

Enter your email address to receive my latest blog posts: 


Random Articles

  • Brain-controlled Teleport

    I was invited to demonstrate my robots on a QANTAS flight from Sydney to San Francisco, while we flew over the Pacific Ocean.  I said yes!  My fellow...

  • How successful are you?

    “I go to Imperial College”, “I’m applying to MIT”, “I play bowls for my county”, or “I’m a pro-series gamer” means nothing to the person who doesn’t know...

  • YouthActionNet Global Fellowship Day 0: The "best" and "better" plans

    A month ago, I came up with a list of the things I wanted to consider during my YouthActionNet Fellowship retreat.  In the 24 hours that it took me...

  • Phoenix, Arizona

    I love exploring new cities! So I was super thrilled to visit Phoenix in Arizona, and speak at ASQ’s Lean and Six Sigma Conference as their opening...

  • A Day in the Life at Singularity University

    From June 13 - August 23, I am staying at NASA AMES Research Park, funded by Google, studying with 80 people from around the world in Singularity...

  • The stars won't align

    I was thinking and plotting and planning my startup. When to begin.  Was it too early?  Was the market ready?  Would I waste my time?  Would I waste my...

  • Aipoly launches!

    We launched Aipoly two days before CES 2016, where we were given a booth for free, as one of five winners of the first CEA Foundation "Technology...

  • Clarity in thought

    Clear away some space and time for yourself. Without the pressure of someone bursting in and occupying your space. By giving yourself the time and...

  • TEDxSydney

    From January - May this year, I worked on the first prototype of the production model of my telepresence robot, Teleroo.Teleroo was launched onstage at the...

  • Aurukun Advance Queensland

    As part of my Advance Queensland Hot Desq tenure, I was granted the unique opportunity to visit a remote Aboriginal community, Aurukun, to encourage kids into...

Enter your email address to receive my latest blog posts: 


Scroll to Top